Figures
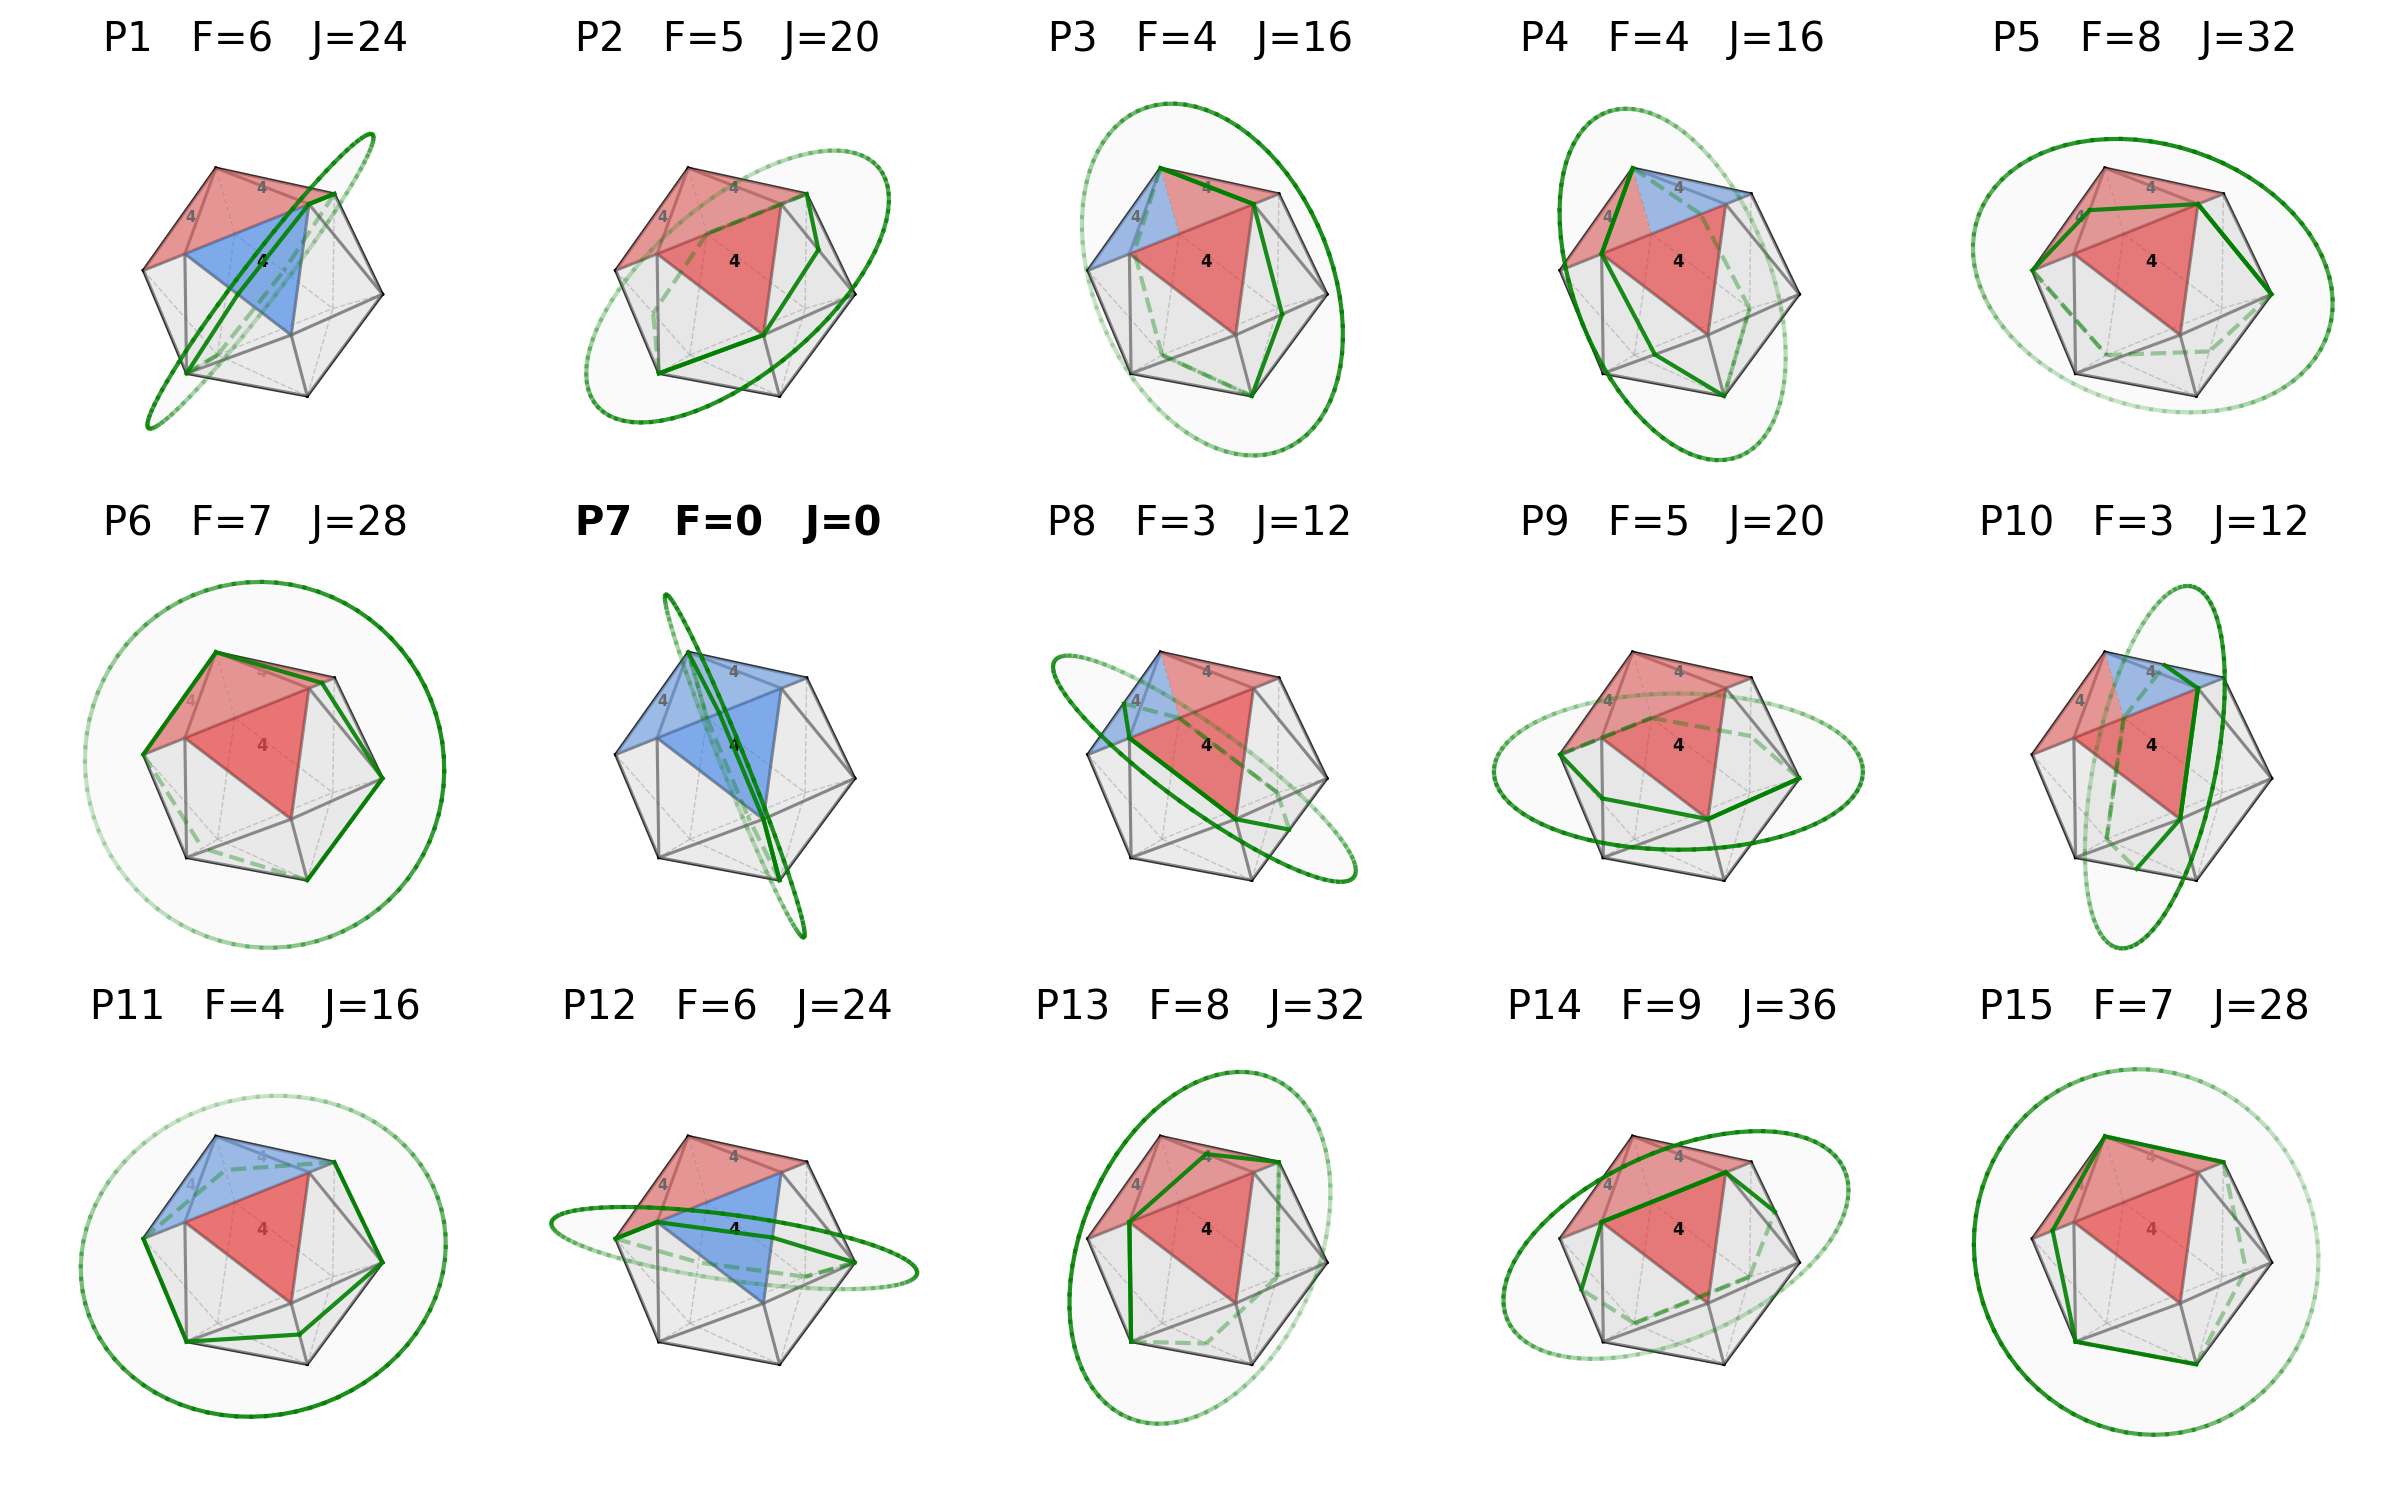
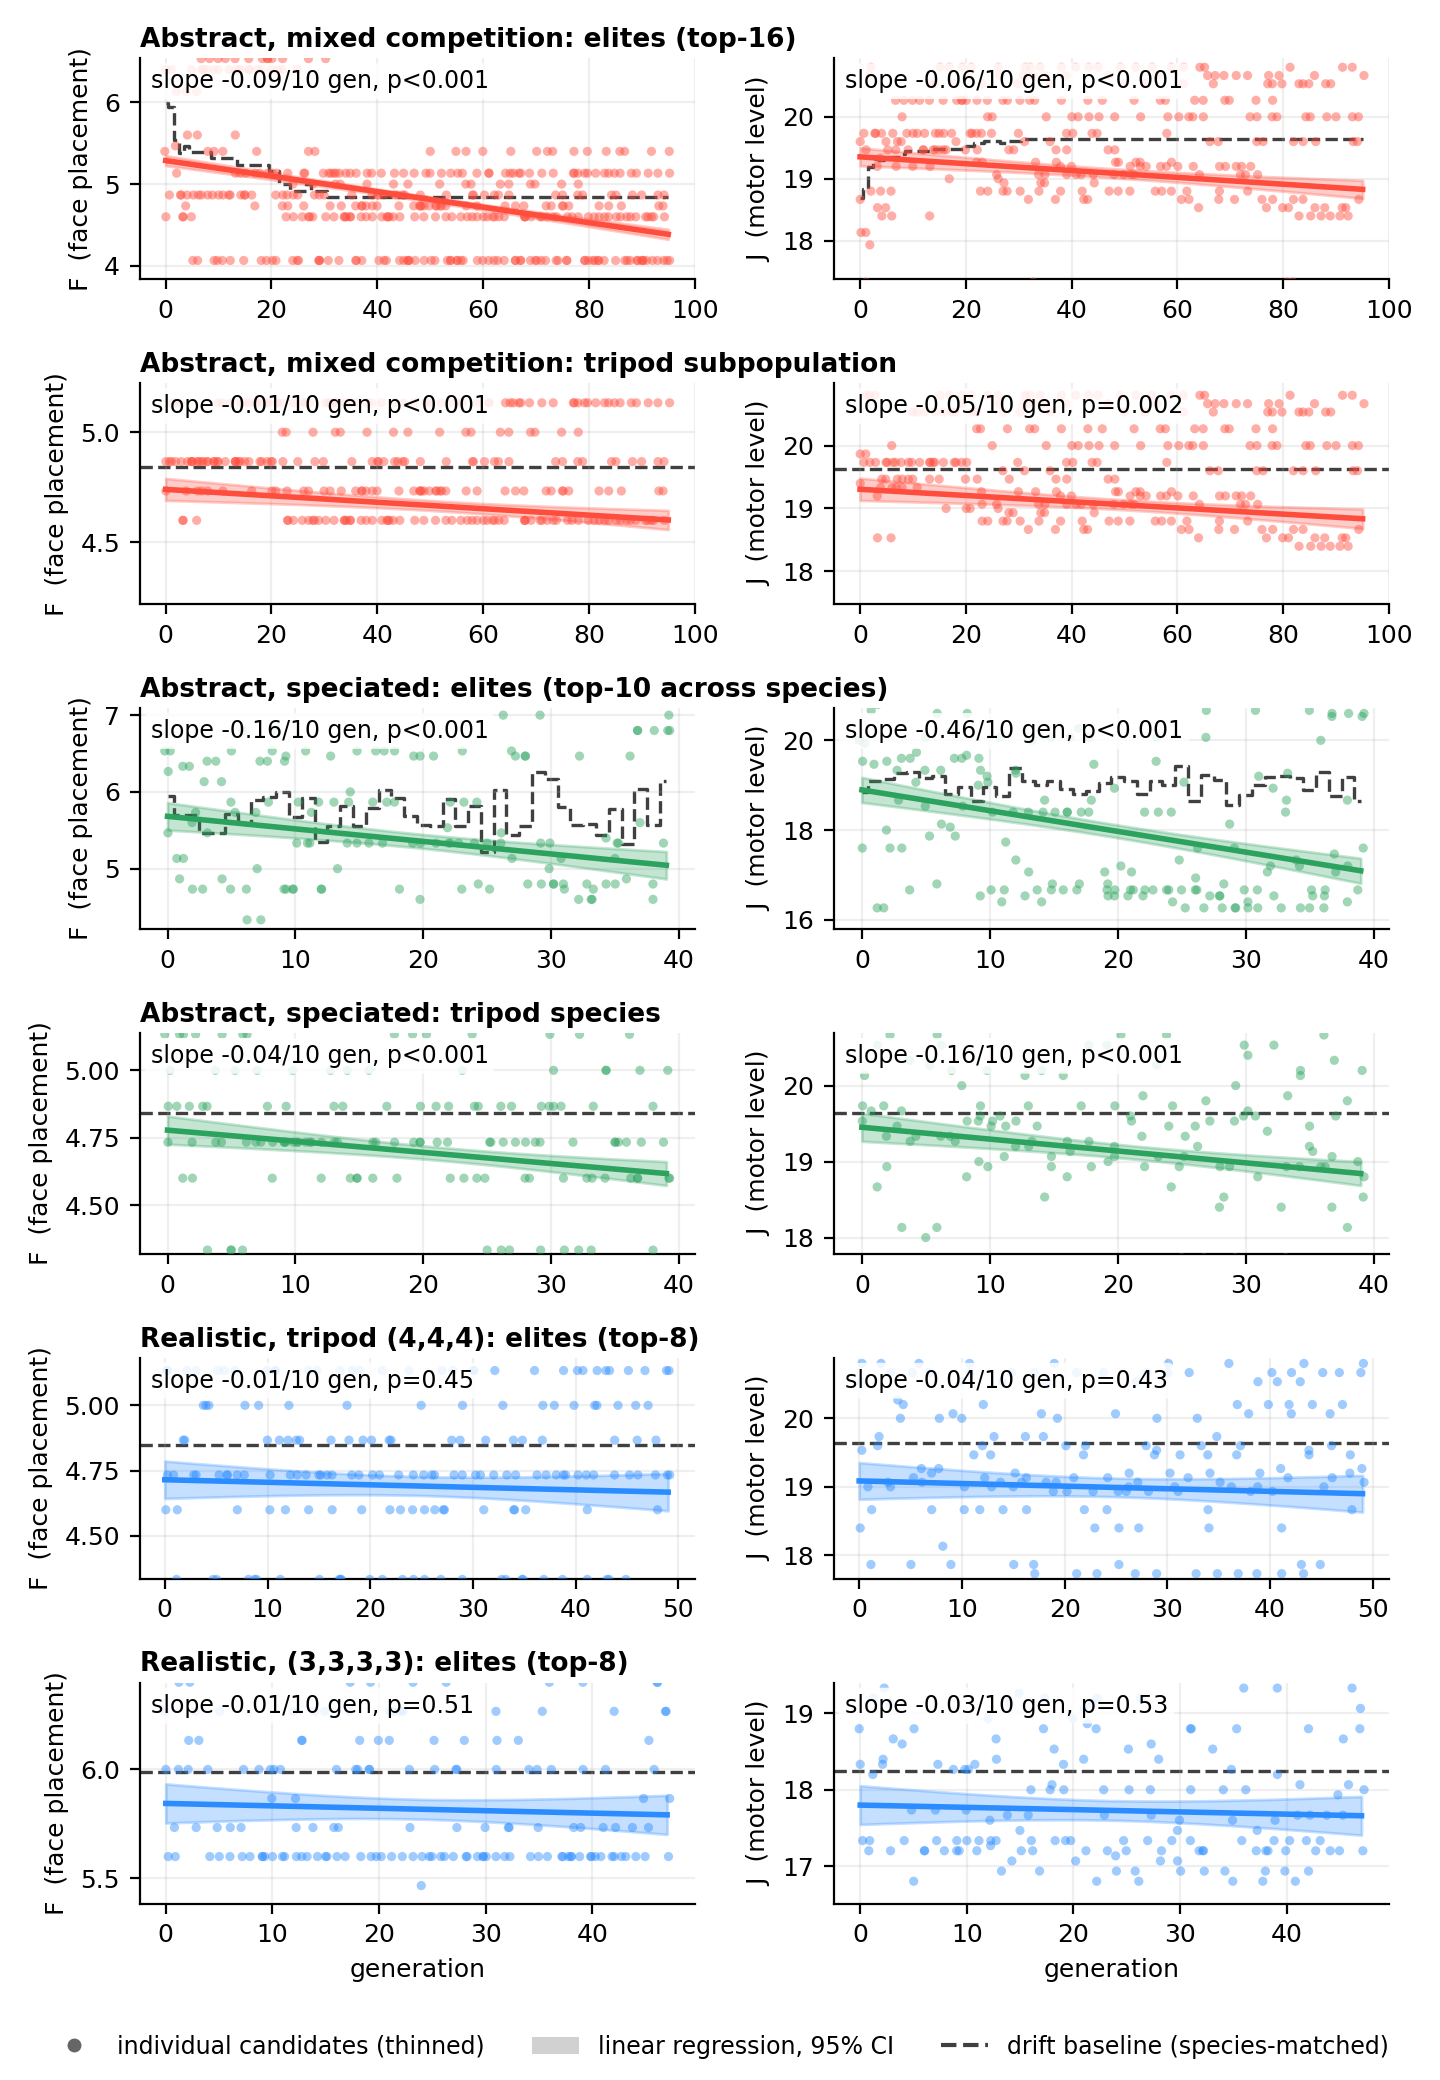
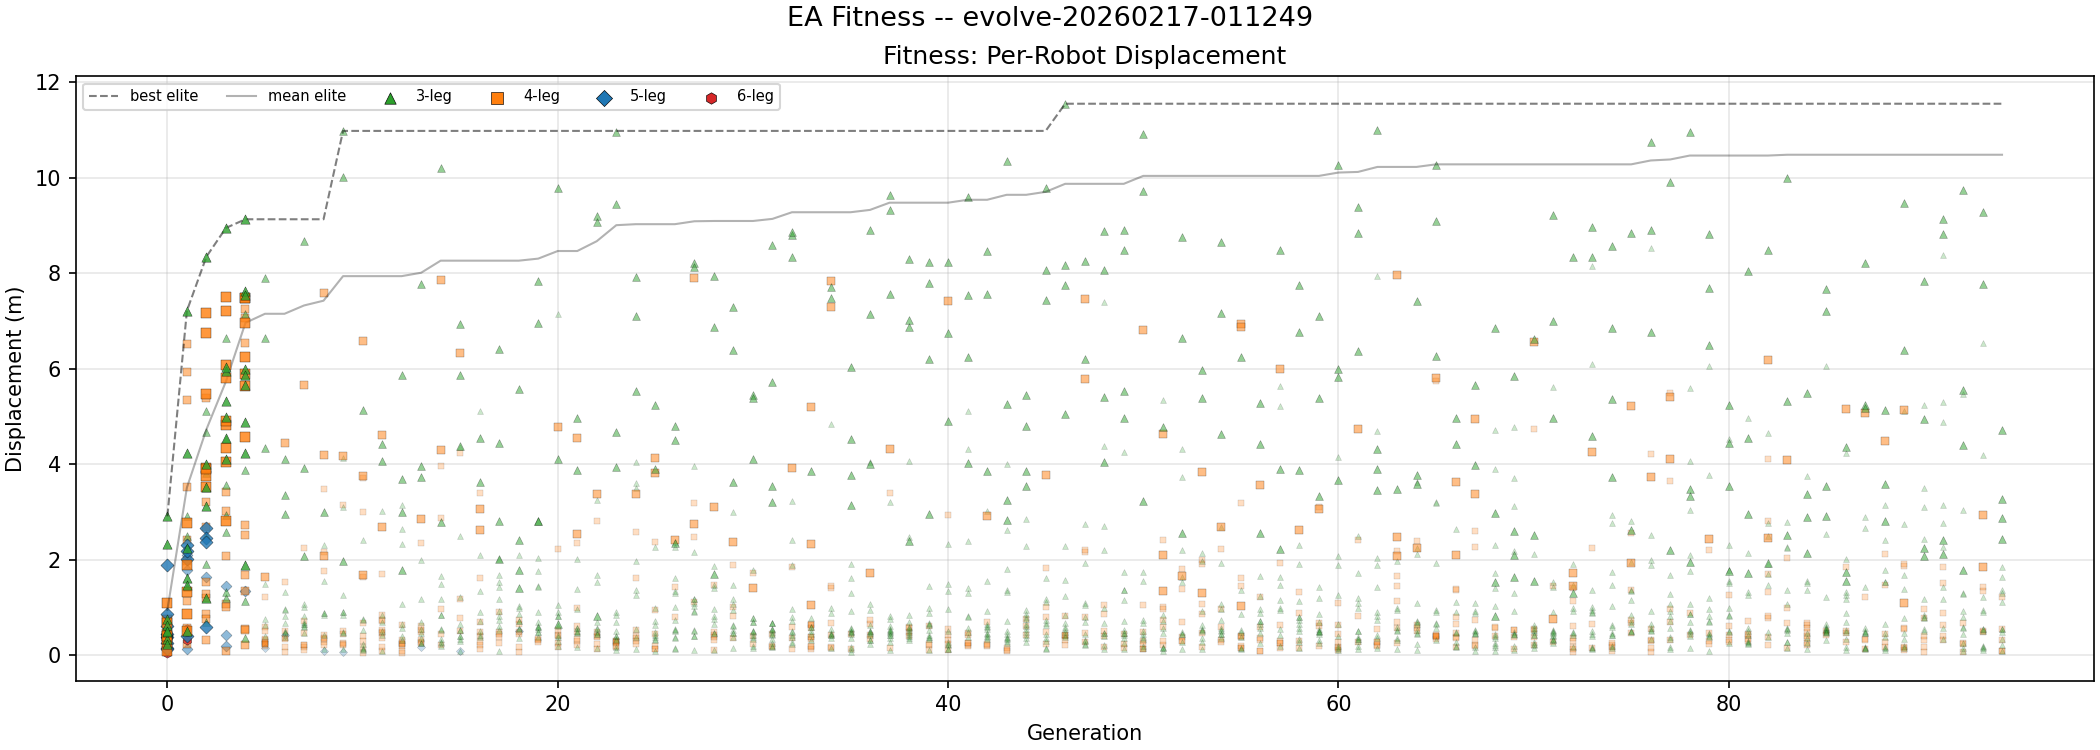
The figures of the abstract, with self-contained captions for readers who arrive here without the paper. Plotting scripts are in vis/.
1 Creative Machines Lab, Columbia University
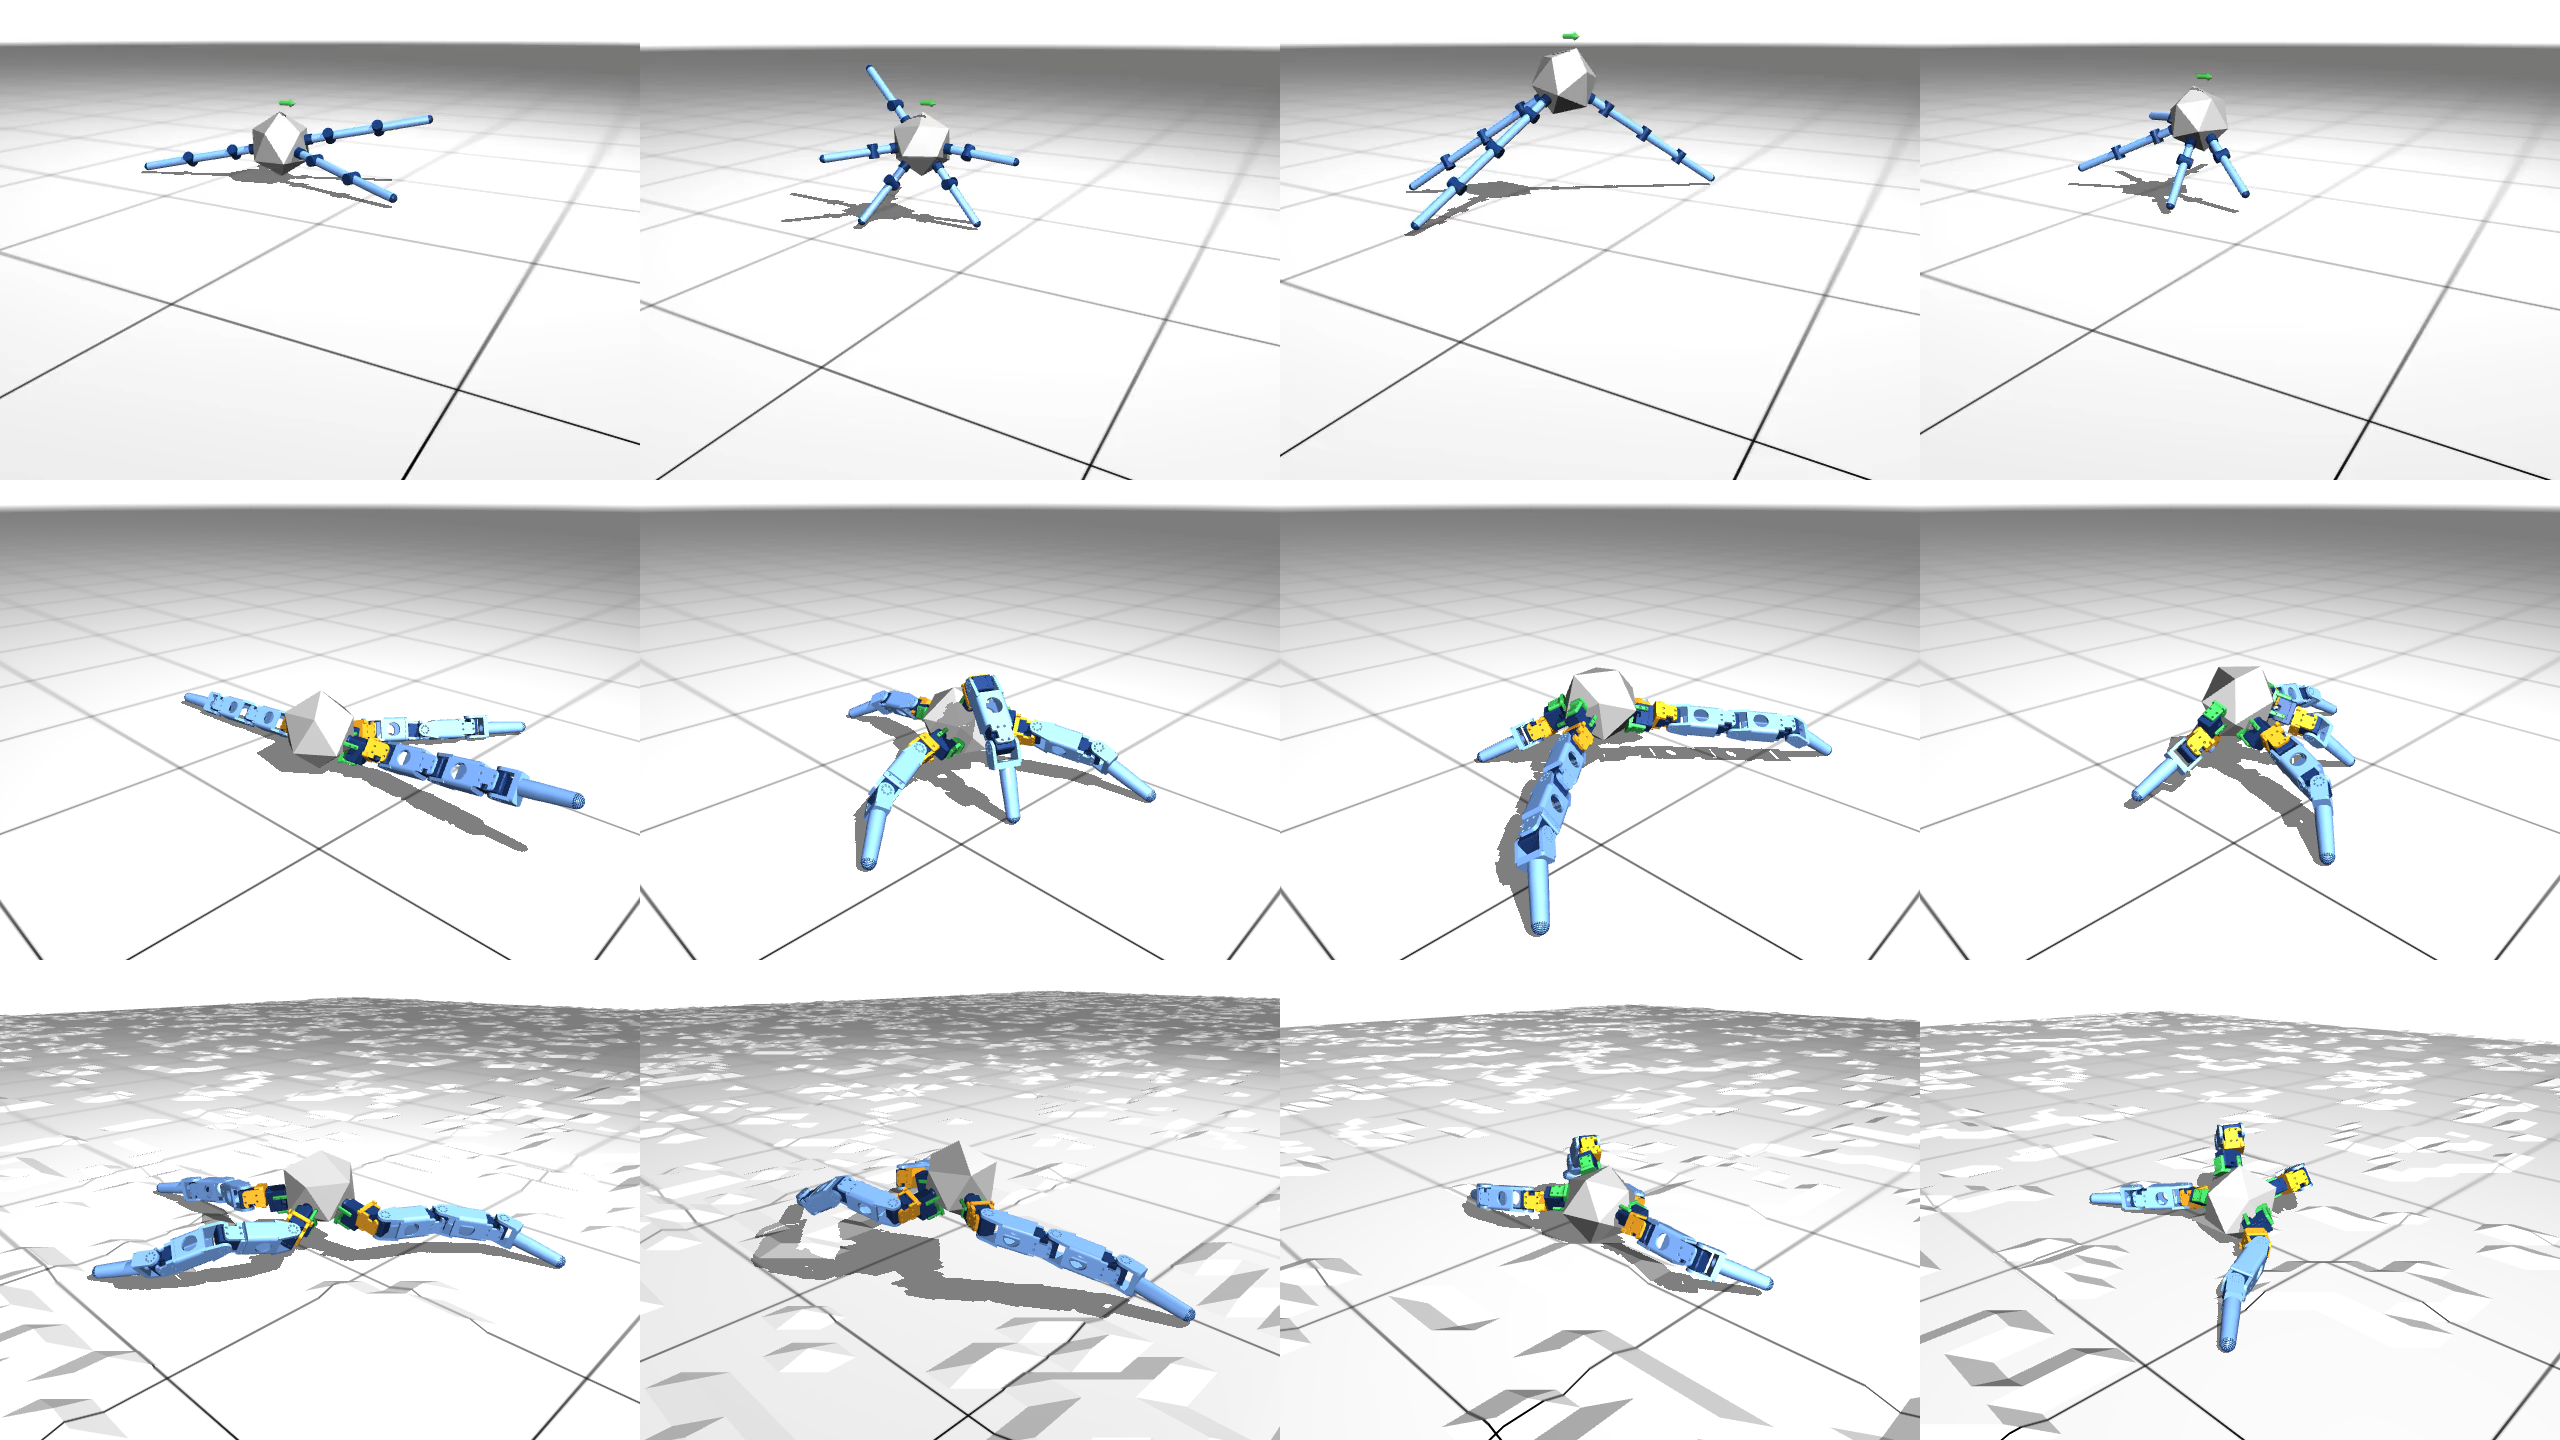
One recorded 20 s rollout per clip, replayed through MuJoCo forward kinematics · abstract space = the original study’s clips (Genesis, position-controlled servos, capsule bodies) · fabricable space = the hw17 build (v50 printed parts, XM430 motor model, domain randomisation) trained in icos_v2, on flat ground and on the quantised 30 mm rough field
Each body in both design spaces. Left: the abstract-space clip from the original study (Genesis, position-controlled servos). Right: the same morphology as the hw17 build trained in this work, on flat ground and on the 30 mm rough field. Numbers are the 20 s displacement of the recorded clip. Click a thumbnail to load it in the viewer.
The figures of the abstract, with self-contained captions for readers who arrive here without the paper. Plotting scripts are in vis/.